Key takeaways
- Junction-box cobots pay off when inserts, covers, and ground screws repeat on a fixed nest.
- Fixture datums beat eyeball offsets when box sizes change every few hours.
- Torque and angle logs turn each fastener into a traceable record for QA.
- Vision fits presence checks on grommets and labels, not full wire-harness routing.
- Operators still own complex wire dress, first articles, and UL-style exceptions.
Should you automate junction-box assembly with a cobot?
Electrical enclosure lines look simple until mix explodes. One shift runs NEMA boxes with knockouts pre-punched, the next adds ground bars, neutral plates, and different cover screws.
A collaborative robot arm earns its place when the same handful of operations repeat: place a ground screw, start a cover fastener, press a gasket, or pick a terminal block into a fixed slot. It struggles when every order is a one-off custom harness shop.
Start with one box family and one station, not every SKU in the catalog on day one.
Which tasks can a cobot own in the cell?
Most cells combine pick, place, and drive. Pick uses a vacuum or finger grip on inserts that sit in a tray nest. Place references datums on the box flange so screw holes line up with the driver bit.
Simple wire routing means feeding a pre-cut lead through a grommet opening when length and bend radius are fixed. Full harness dressing with multiple branches usually stays manual.
Inspection steps often check that a knockout plug is seated or a label is present before the cover goes on. Keep those checks short so cycle time still beats a tired hand at hour ten.
- Pick inserts from tray or bowl feeder
- Place into pocket with vision offset limit
- Drive screw with logged torque and angle
- Optional presence check before cover install
How should fixtures handle high-mix box sizes?
Swap fixtures or sliding nests beat reprogramming from scratch. Each box size gets a mechanical stop set and a stored recipe name tied to a work order barcode.
Quick-change dowels and labeled nests reduce wrong-box setups when two similar enclosures differ by a half inch of depth.
Run first-article checks after every fixture change. Operators sign the sheet before production volume restarts.
Where does vision help without overpromising?
Cameras excel at binary questions: is the gasket present, is the knockout closed, did the label land right-side up. They are weaker when wire tails fan in random directions after manual pre-assembly.
Limit search regions so glare from galvanized boxes does not false-trigger. Matte reference tiles on the nest help.
When vision fails twice in a row, route the box to a manual rework lane instead of letting the arm guess.
Why do torque records matter on enclosure lines?
Cover screws and ground lugs often carry audit questions after a field callback. A smart driver on the cobot logs torque and angle per cycle with a timestamp tied to the serial or lot code.
That record does not replace your listing lab work. It does shorten internal investigations when someone asks if a batch skipped a ground path.
Store logs where quality can export them without opening the robot teach pendant.
How do changeovers work on a high-mix line?
Treat recipes like CNC programs: name, version, owner. Loading a new box size should take minutes on the HMI, not a laptop on the floor.
Keep manual steps documented for operations the cobot does not own yet. When you add one, update the work instruction in the same change ticket.
Batch sizes of five to twenty boxes are common in panel shops. Optimize for fast changeover, not single-piece flow unless your orders truly justify it.
What manual work should stay with people?
Complex wire dress, multi-branch harnesses, and odd knockout patterns belong with experienced assemblers. So do judgment calls on damaged enclosures or wrong UL markings spotted at receiving.
BLS groups electrical and electronic equipment assemblers among production occupations with repetitive hand work and quality scrutiny. Automation should peel off the motions that cause fatigue, not the sign-offs that carry liability.
Train operators to clear jams without bypassing interlocks. A grounded enclosure line is not the place to defeat a light curtain because the shift is behind.
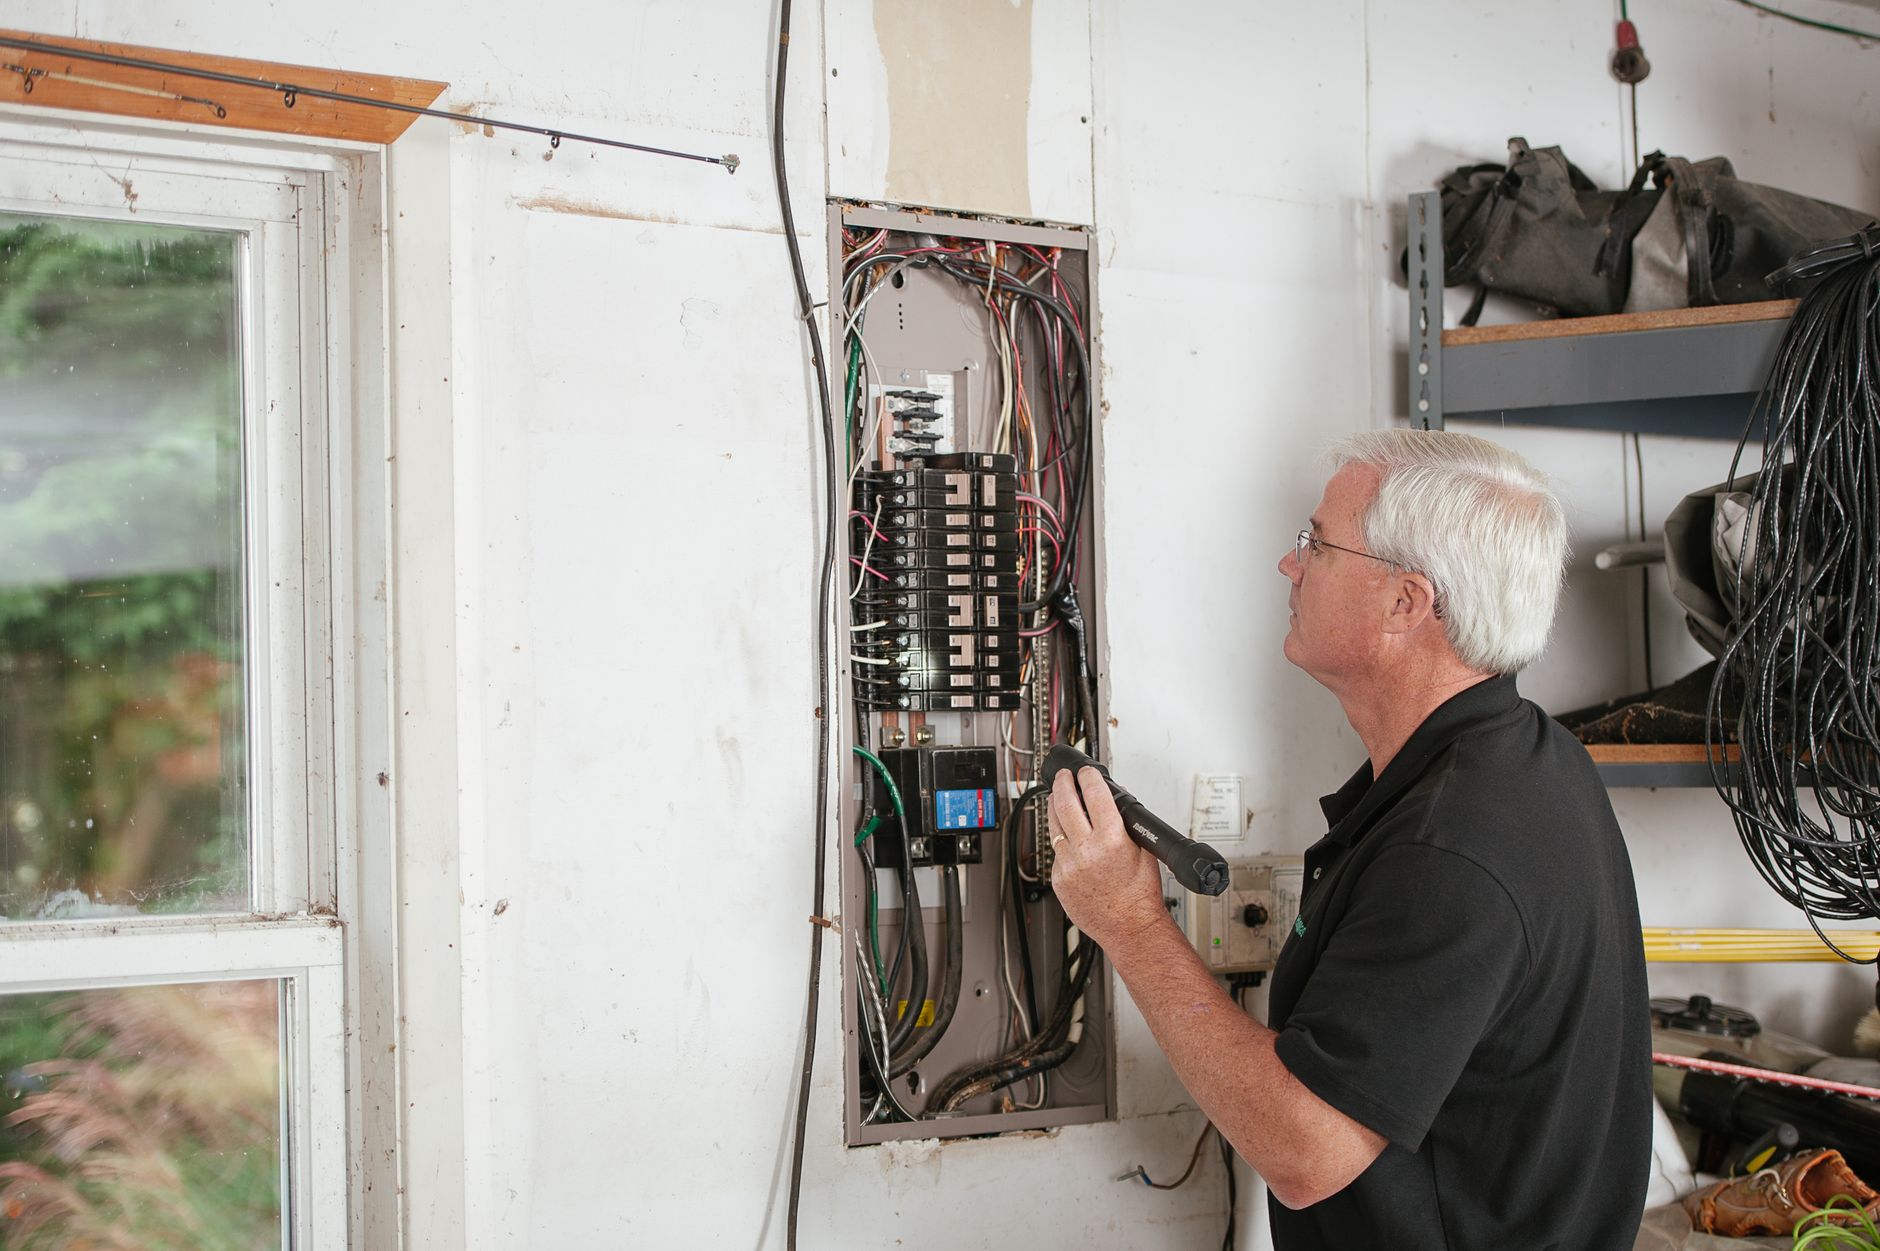
What labor context makes the business case honest?
May 2023 national OEWS data lists about 267,440 electrical, electronic, and electromechanical assemblers with a mean wage near $21.03 per hour. Shops feel pressure from mix and rework cost as much as from headcount.
Cobots rarely delete a role on a ten-person bench. They stabilize output when temps rotate or when one experienced assembler is out sick.
Pair any cell with a redeployment plan: more final test, more kitting, or faster changeovers instead of a vague labor savings slide.
How should you pilot a junction-box cobot cell?
Film ten manual cycles at the target station. Count dropped screws, mis-started bits, and boxes sent to rework.
Service Robot Co. matches payload and reach to your bench height, integrates torque tools and vision, and can finance the cell monthly while you prove trace data on live orders.
Run four to six weeks on one box family before adding a second nest. Expand only when QA trusts the torque log export and operators stop fighting the fixture.